Skip to projects
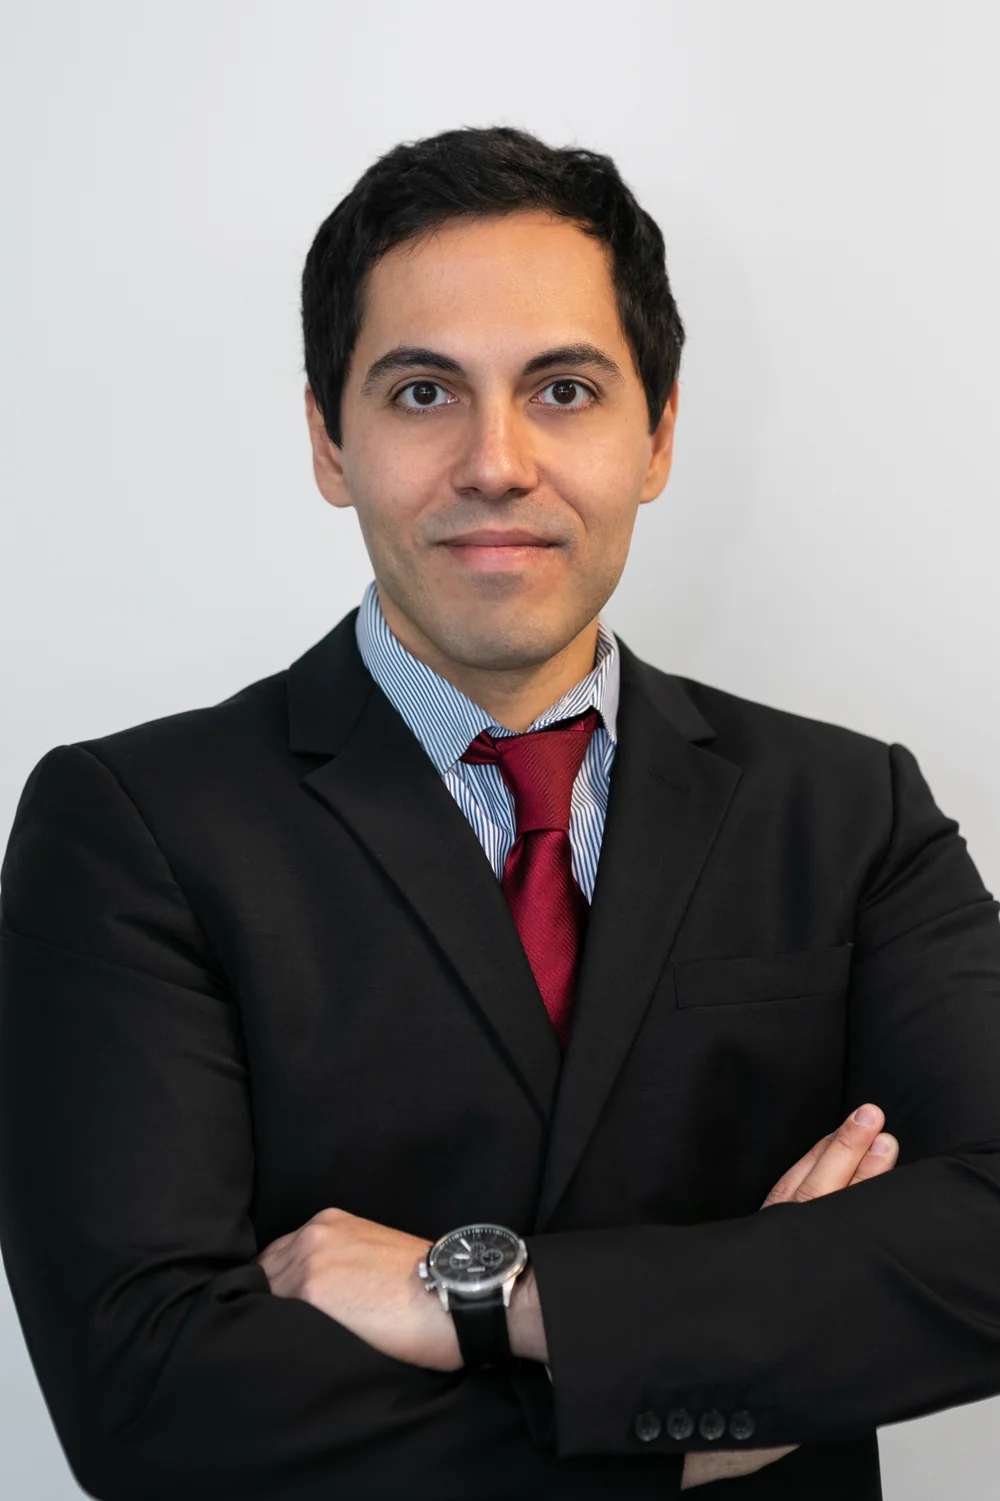
Oney Erge

Oney Erge

Applied AI and Physics, Research and Engineering

  • PhD, UT Austin
  • 32+ papers
  • 8 patents
  • 800+ citations
  • Houston, Texas

I enjoy the intersection of AI, physics, and engineering. I've worked across agents, robotics, simulation, machine learning, and physical modeling, and I'm especially drawn to emerging problems where scientific ideas can lead to practical results.

Projects

These are some of the projects I work on in public, from local agents and full-precision inference on small GPUs to simulation environments where agents learn from physical outcomes. I hope they are useful to you in one way or another.

  1. Policy protected

    Agent systems

    YBM

    A policy-protected local agent that keeps working toward the task.

    Talk to it from the web, Telegram, or WhatsApp, and approve important actions before they run.

    • Policy-gated tools
    • Self-extending workflows
    • Local-first
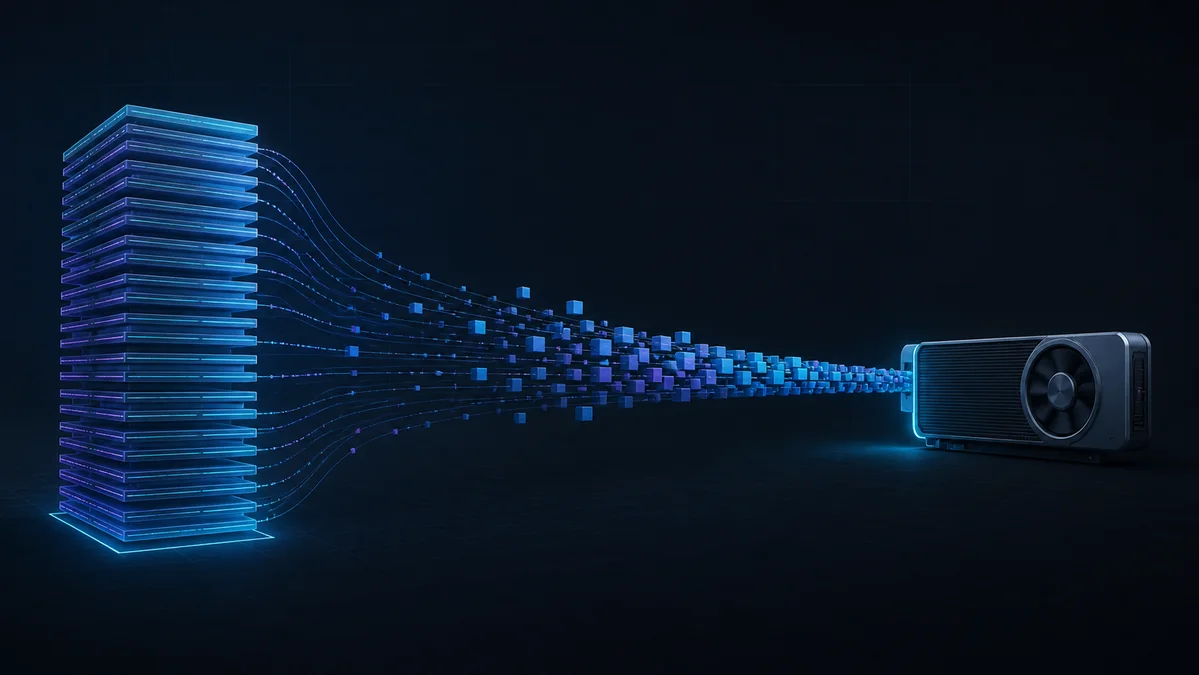
  2. Model layers streaming from storage through memory to a smaller GPU
    29.5 GB modelon8 GB GPU
    Lossless weight streaming

    Inference systems

    Afterimage

    Run large, full-precision models on smaller GPUs.

    It ran a 29.5 GB model on an 8 GB GPU by streaming losslessly compressed weights one layer at a time.

    • Lossless compression
    • CUDA memory streaming
    • Inference research
  3. Choose · deploy · measure

    Local AI

    LocalDeploy

    A complete local model deployment and benchmarking suite.

    It checks your hardware, estimates which models fit, and measures the speed, quality, and memory you actually get.

    • Hardware-aware deployment
    • Model benchmarking
    • Runtime orchestration
  4. AgentGymnasium tiny city simulation previewCITY_PULSE / SCORE 100%

    Agent evaluation

    AgentGymnasium

    Bring AI agents and physics into the same experiment.

    An agent builds something in a simulated world, sees what happened, and gets another chance to improve it.

    • Agent evaluation
    • Physics simulation
    • Reproducible trials
  5. RUN / OBSERVE / DIAGNOSE

    Robotics

    Creature Lab

    Design, evolve, and test robots in a reproducible physics lab.

    Edit a robot body, run it in physics, and trace a failure to the body, controller, task, or simulator.

    • Robot morphology
    • Evolutionary search
    • PyBullet
  6. CONFIG / TRAIN / INFER

    Computer vision

    SegCraft

    Train, compare, and run semantic segmentation from one platform.

    One setup trains a segmentation model, compares it, and runs it on images or videos.

    • Semantic segmentation
    • Model comparison
    • Video inference
More on GitHub

Writing

Notes on LLM inference, memory use, and performance.

All writing

Experience

  1. WorkOxy

    AI Lead, Language Modeling Engineering

    I lead NLP and language-model engineering in Oxy's Applied AI Center of Excellence.

  2. WorkDeloitte

    AI Lead

    I was responsible for 19 models from problem definition through deployment, spanning machine learning, NLP, and optimization.

  3. Editorial serviceJGSE

    Associate Editor

    I served for more than 10 years as an Associate Editor, overseeing peer review and editorial decisions for more than 250 scientific manuscripts.

  4. WorkDow

    Senior Research Specialist

    I published 4 internal technical papers on signal processing, data-driven modeling, and decision-making. I also led the assessment and integration of Boston Dynamics Spot and other quadruped robotic platforms.

  5. WorkRobotics Startup

    Data Scientist / Robotics Software Engineer

    I developed a custom SLAM and sensor-fusion method for an omnidirectional mobile robot, using motor effort and onboard sensing to estimate and correct motion drift for better pose estimation.

  6. Research and educationThe University of Texas at Austin

    PhD, Dynamic Systems and Control · Portfolio in Applied Statistical Modeling

    My doctoral research focused on hybrid modeling: combining AI and physics to improve prediction and control in physical systems. Doctoral dissertation SciPy paper

  7. WorkSLB

    Data Scientist / Software Engineer

    I worked across the full software and data-science lifecycle of ABBL, from pattern-recognition models through product development and commercialization. The automated directional-drilling adviser was tested across more than 250 wells. ABBL service

  8. Research and educationThe University of Tulsa

    MSc, Petroleum Engineering

    My MSc research combined experiments and numerical methods for non-Newtonian flow and freely rotating drillstrings. I later collaborated on work pairing a deep-learning model with genetic-algorithm optimization. Request master's thesis Genetic-algorithm paper

  9. EducationMiddle East Technical University

    BSc, Petroleum and Natural Gas Engineering

    I built my engineering foundation in transport phenomena, numerical methods, and subsurface systems.

Research

800+
Citations
32+
Publications
15
h-index
8
US patents

Contact

I am easiest to reach on LinkedIn. I am always glad to hear from people working on agents, local AI, simulation, or AI for physical systems.

Connect on LinkedIn